Who this fits
For teams that need a professional upper-limb actuator supplier to solve space, mass, cable path, and repeatability constraints.
Custom compact actuator modules for humanoid arms, wrists, elbows, shoulders, necks, and hands where low mass, quiet motion, cable routing, and fine control matter.
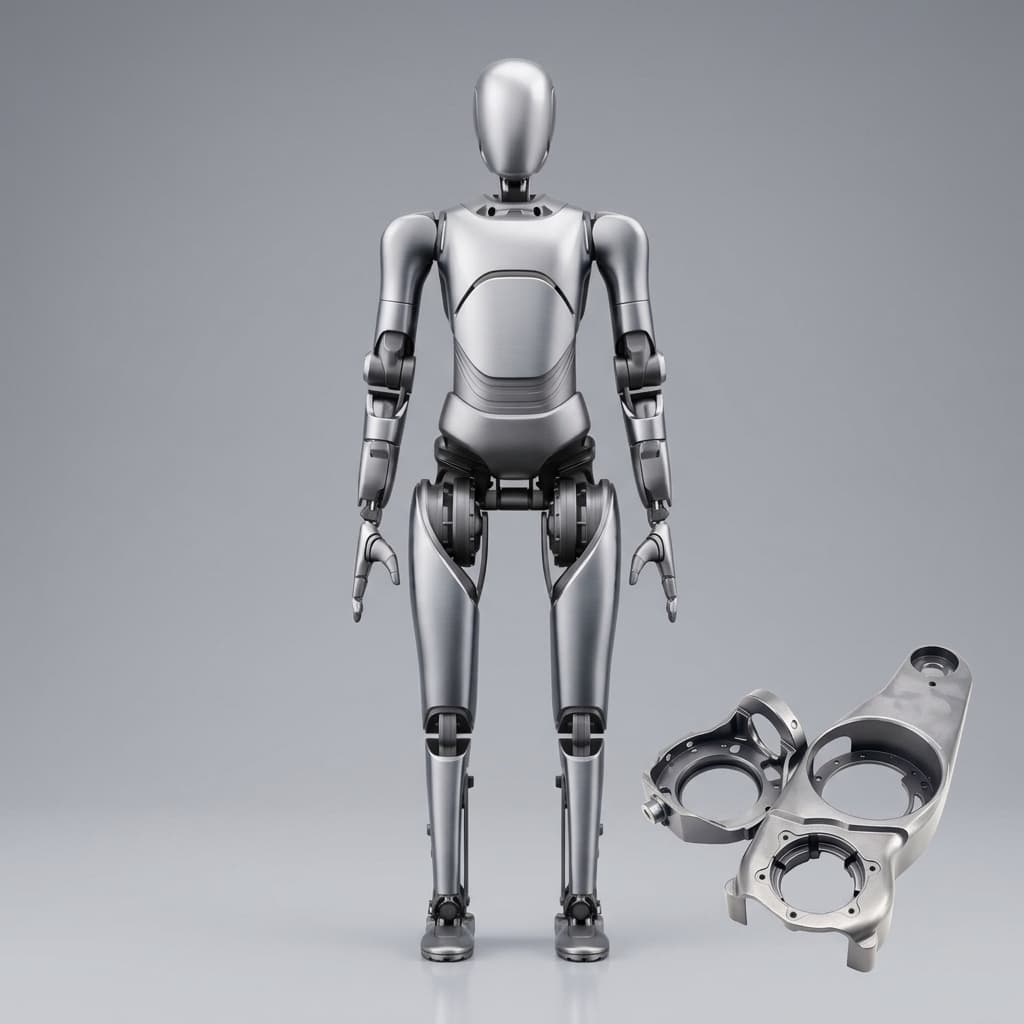
This page should help a robotics buyer decide whether this product family belongs in the RFQ path and what evidence must be attached before a prototype or pilot order is credible.
For teams that need a professional upper-limb actuator supplier to solve space, mass, cable path, and repeatability constraints.
Mass budget: Upper-body joint dependent
The actuator fits one side but fails mirrored left/right assembly
| Metric | Typical Range | Why It Matters |
|---|---|---|
| Mass budget | Upper-body joint dependent | Arm and wrist mass affects payload, dynamic control, battery life, and the sizing of upstream shoulder joints. |
| Cable routing | Side exit, rear exit, or hollow path | Connector conflicts often block otherwise acceptable actuator designs inside humanoid limbs. |
| Low-speed smoothness | Reducer and control dependent | Manipulation and head-motion joints need smooth motion rather than only high peak torque. |
Product selection is only useful when it connects to a buyer-visible evidence path. These proof gates turn the page from a capability description into an RFQ checklist.
| Proof Gate | Evidence to Ask For |
|---|---|
| Drawing baseline | CAD package, controlled drawing revision, CTQ list, open trade-offs, NRE scope, and prototype/pilot responsibility. |
| RFQ evidence package | Buyer-side package with joint map, CAD/drawing baseline, torque-speed or force-stroke targets, validation request, pilot quantity, and report expectations. |
| Evidence library | Stage-by-stage map for CMM, FAI, actuator validation, electronics/FCT, traceability, NCR, packaging, and pilot release records. |
| Test plan checklist | Operating cycle, fixture boundary, torque-speed or force-stroke method, thermal-rise setup, backlash method, FCT, endurance, and report handoff. |
| Sample PO checklist | Drawing revision, CTQ acceptance limits, report deliverables, sample variants, buyer-supplied boundaries, change rules, packaging, and delivery records. |
| Manufacturing proof | FAI, CMM, datum checks, bearing fit, flange flatness, output runout, surface treatment, and outgoing reports. |
| Actuator validation | Torque-speed, thermal rise, backlash, noise, FCT, burn-in, traceability, nonconformance, and pilot release records. |
| BOM and sourcing control | Approved parts, restricted suppliers, substitutions, lead time, firmware boundary, harness, packaging, and second-source risk. |
A serious custom actuator inquiry should show how the selected product family moves from feasibility review into repeatable pilot manufacturing.
Review CAD, joint load, envelope, thermal boundary, cable path, and custom actuator architecture risk.
Build the first sample against defined torque-speed, fit, electrical, mechanical, and inspection assumptions.
Run thermal, backlash, noise, endurance, impact, metrology, and functional checks against the application duty cycle.
Freeze drawing/BOM revisions, evidence package, outgoing inspection, packaging, spare strategy, and repeat-build controls.
This form is prefilled with Compact Humanoid Arm and Wrist Actuators. Add CAD envelope, torque-speed target, duty cycle, validation needs, quantity, and schedule so the response can start with DFM questions instead of generic sample pricing.
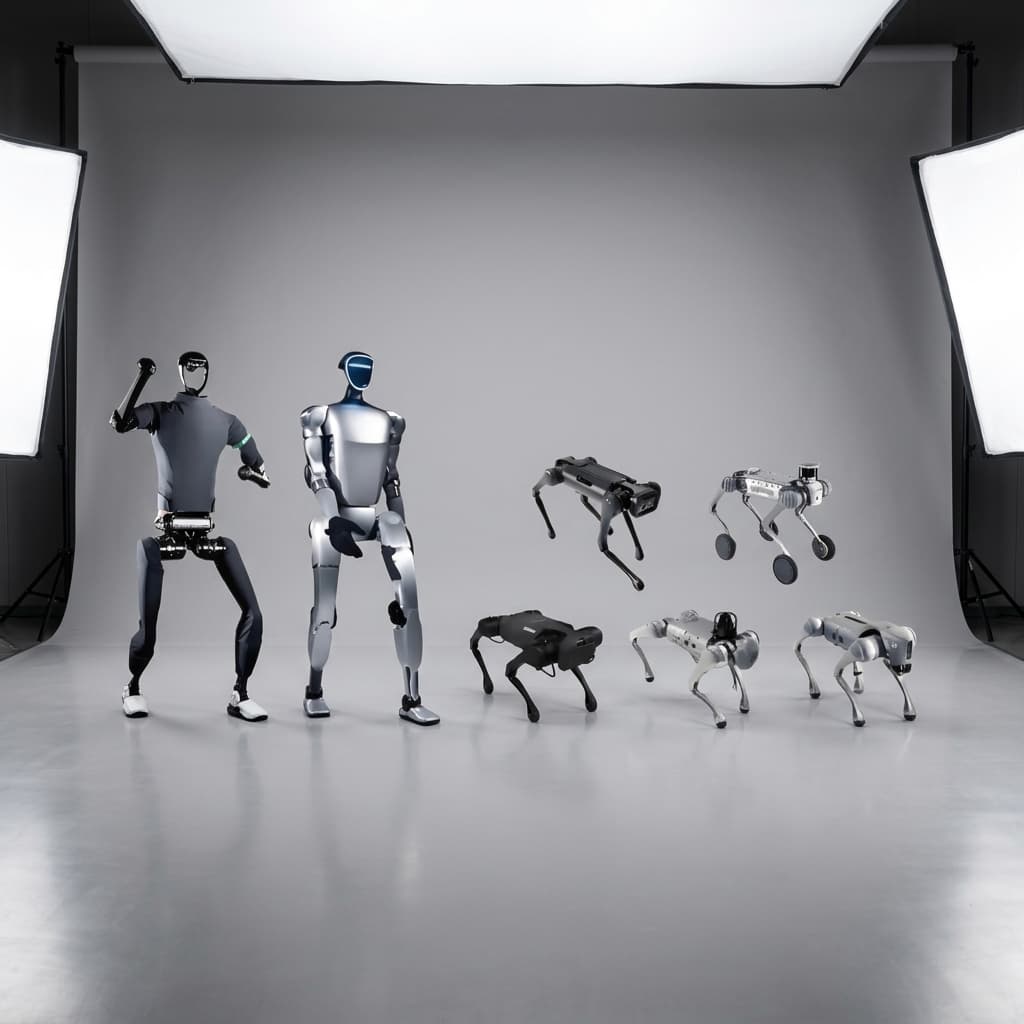
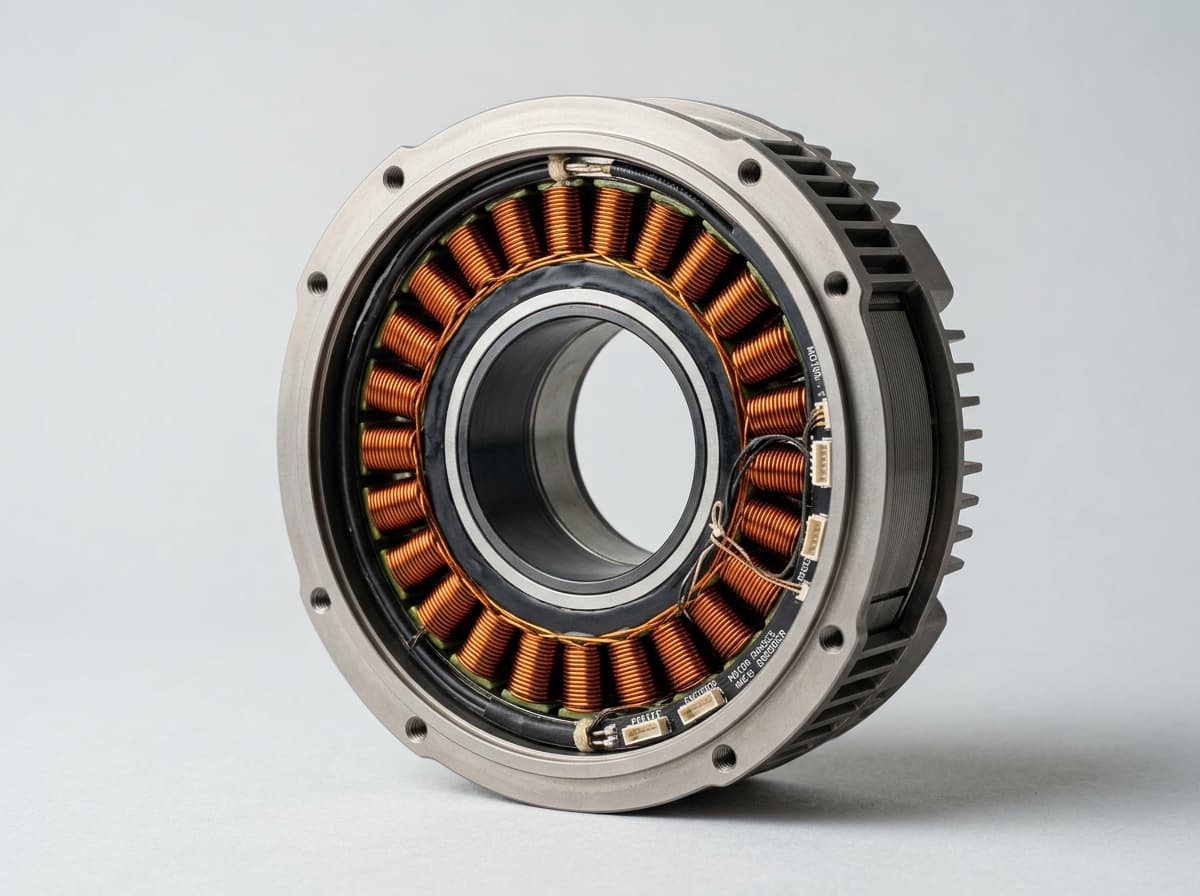
Yes. Send the envelope and key torque-speed requirements. We can review compact motor, reducer, housing, and wiring options.
Yes. Connector location, harness length, cable exit direction, and strain relief can be included in the mechanical review.
Inquiry Email
Include target torque/speed, quantity, and delivery location.
Application Engineer
+8618857971991
Talk directly about drawings, torque-speed targets, and RFQ data gaps.